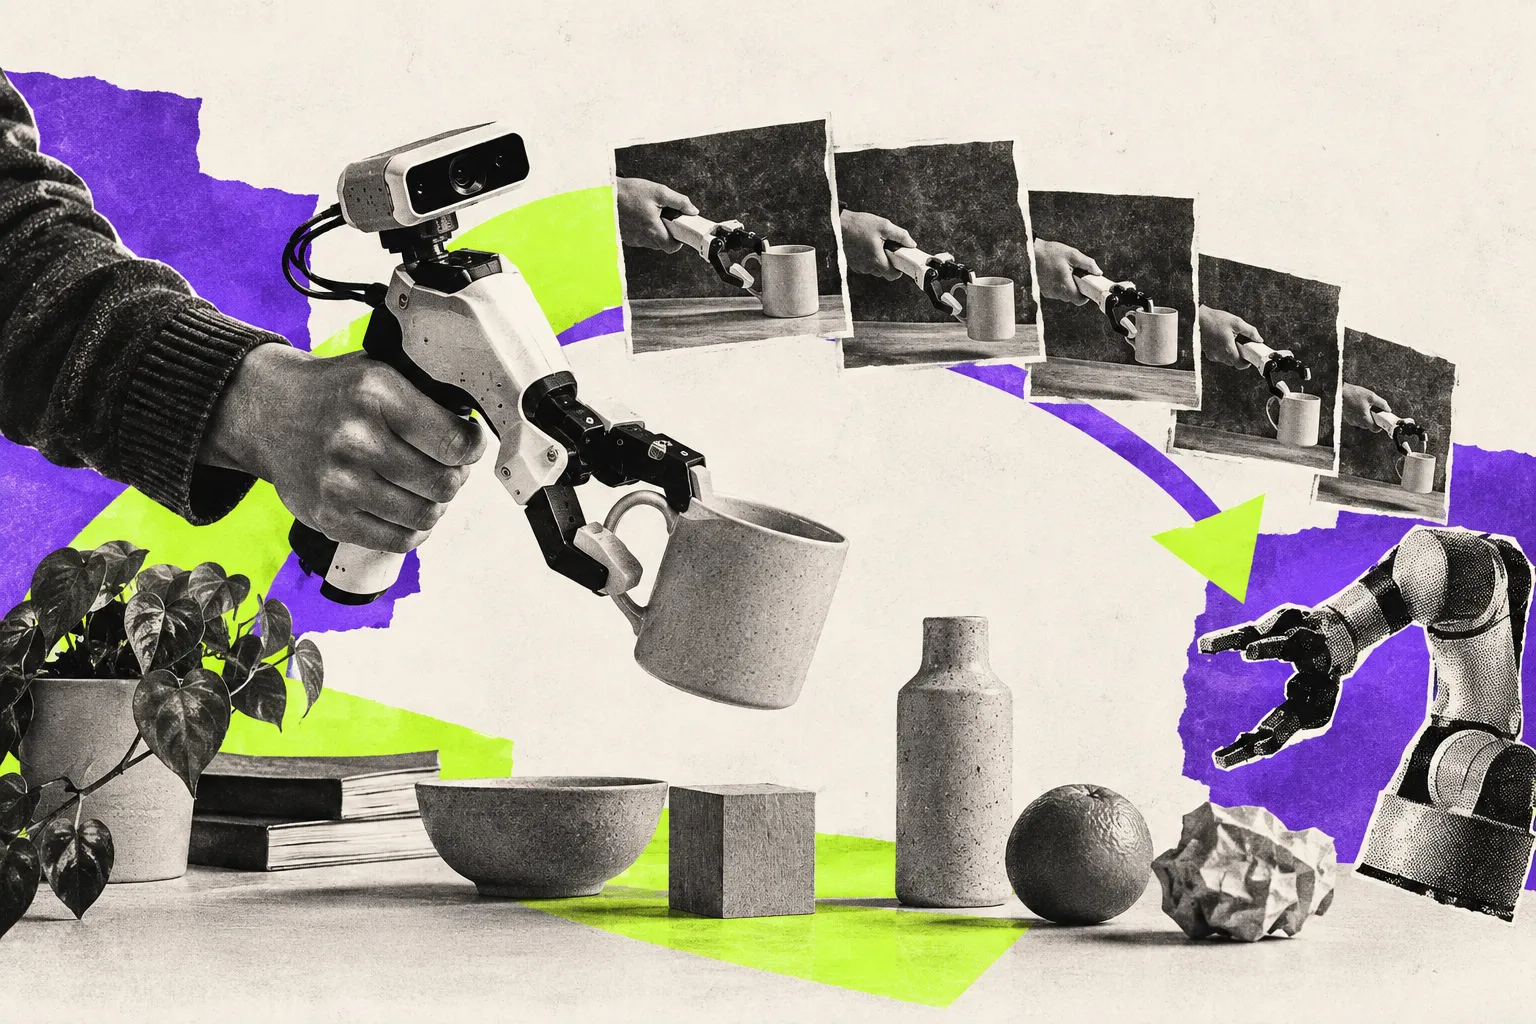
Pollen Robotics introduced Grabette through Hugging Face: a handheld gripper, camera, and tracking workflow for recording manipulation data. Human demonstrations can be converted into robot-ready datasets, with the project aiming to grow a shared collection of examples.
Context
Data collection is a major practical constraint in robot learning. Making demonstrations easier to capture could broaden the situations represented in training. The next challenge is transfer: different hands, grippers, and environments do not produce interchangeable behavior automatically. Recording data cheaply is useful when its limitations remain visible.
Sources & authors
- Grabette: an open system to record robot-manipulation dataHugging Face · July 21, 2026